PATROL WITHOUT
ANNOUNCING
YOUR PRESENCE.
Hydrogliss patrols submerged using actuated fins.
- MODE
- SUBMERGED PATROL
- FIN CONTROL
- ACTIVE
- NAVIGATION
- ACTIVE
- STATUS
- PROTOTYPE
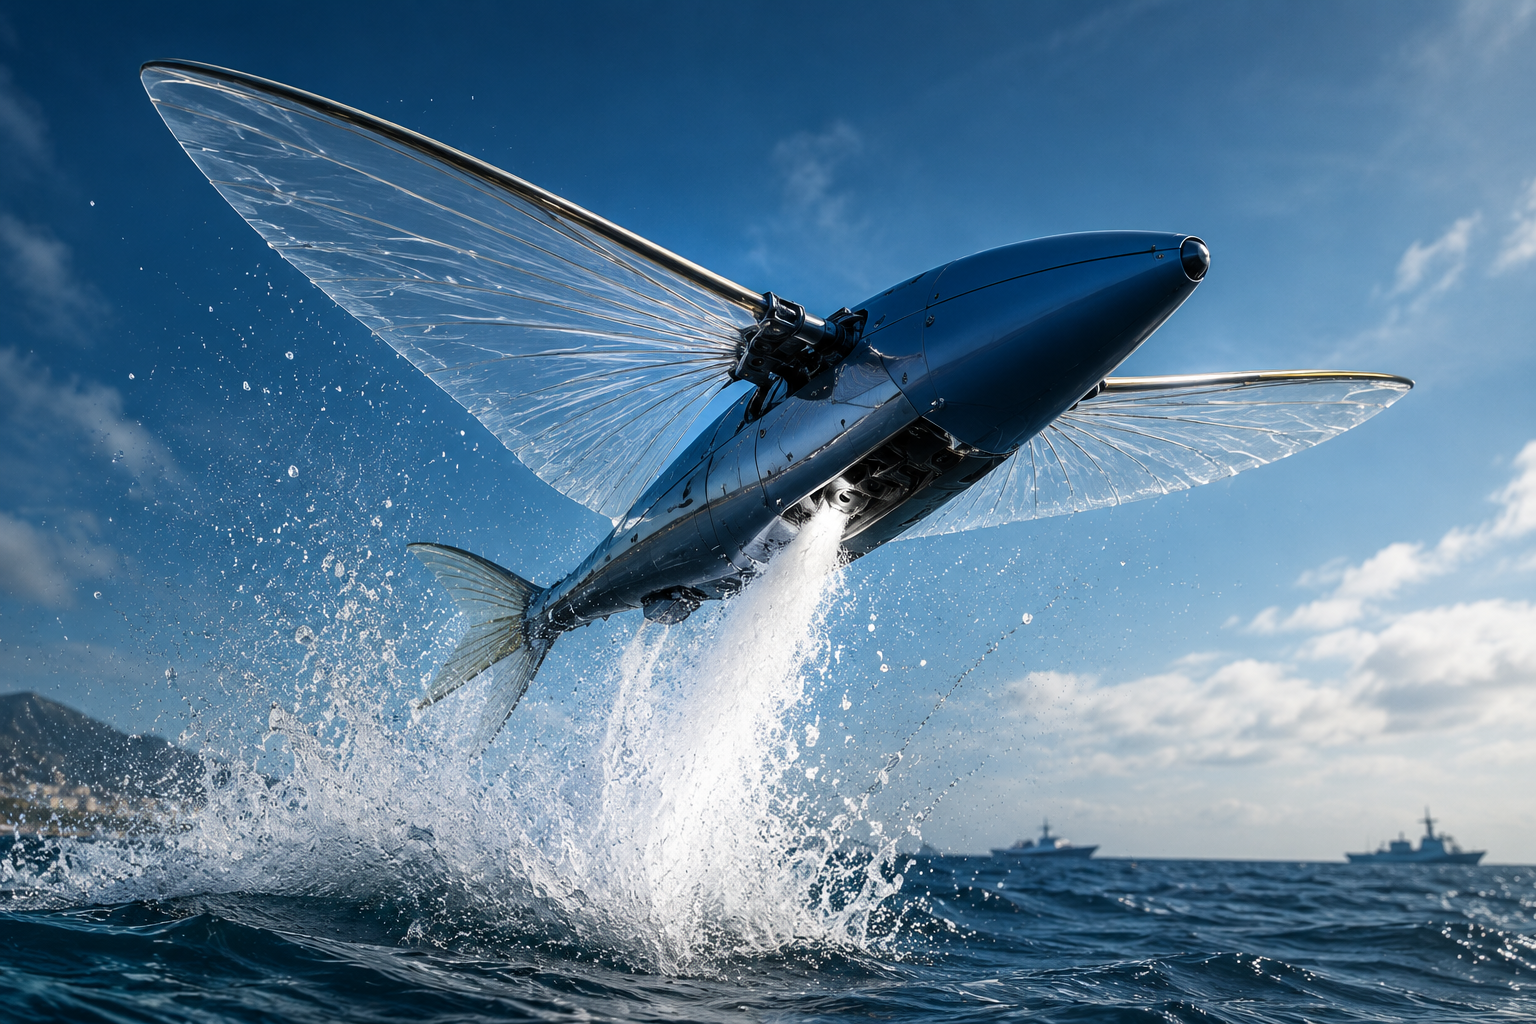
FROM WATER
TO AIR.
A CO₂-assisted launch architecture designed to transition the platform from submerged operation into aerial glide.
- CO₂ burst / launch-chamber bench tests
- ● Tested
- Full water-to-air open-sea transition
- ○ Planned
SEE BEYOND
THE WATERLINE.
Designed to extend sensing and communication beyond the limits of a submerged platform.
- LIVE VIDEO
- ○ PLANNED
- TELEMETRY
- ○ PLANNED
- EDGE AI
- ○ PLANNED
- AERIAL GLIDE
- ○ PLANNED
ENGINEERED
FROM THE INSIDE OUT.
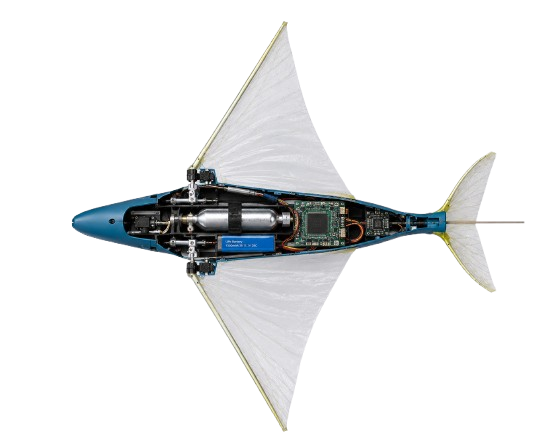
- C-01CO₂ LAUNCH CHAMBER
- C-02SERVO / FIN ACTUATORS
- C-03MICROCONTROLLER / COMPUTE
- C-04SENSOR SYSTEM
- C-05LiPo BATTERY
- C-06SEALED ELECTRONICS
- C-07COMPOSITE STRUCTURE
● TESTED
- Full CAD
- CO₂ burst / launch-chamber bench testing
- Fin actuation
- Control logic
◐ PROTOTYPE
- Integrated amphibious platform
- Composite hull
- Actuated fins
- CO₂ launch system
- Sealed electronics
○ PLANNED
- Open-water water-to-air trial
- Wing deployment / glide
- Live video and telemetry
- ROS 2 + edge-AI autonomy
- Re-entry
- Swarm operation
- Modular mission payloads
AIR ISN’T THE DESTINATION.
IT’S ANOTHER DOMAIN.
Full mission sequence / ○ Planned
- S-01
PATROL
Submerged transit using actuated fins.
- S-02
LAUNCH
CO₂-assisted breach of the surface.
- S-03
OBSERVE
Sensing above the waterline.
- S-04
RELAY
Link data back to the operator.
- S-05
RE-ENTER
Return to the water column.
- S-06
CONTINUE
Resume the patrol loop.
The complete patrol → launch → observe → relay → re-enter cycle is planned, not yet demonstrated in open water.
NOT REMOTE CONTROL.
INTELLIGENCE.
AUTONOMY AT THE EDGE.
Designed for autonomous operation at the network's edge — where connectivity is intermittent and decisions must be made locally in real time.
○ Architecture planned — not yet deployed
EDGE PROCESSING
Onboard compute for real-time perception, classification, and navigation without cloud dependency.
SWARM COORDINATION
Multi-agent communication architecture for coordinated patrol coverage across extended maritime zones.
SENSOR FUSION
Multi-modal sensing designed to combine underwater acoustics with above-surface visual and radio intelligence.
MISSION AUTONOMY
Waypoint-following, obstacle avoidance, and return-to-base logic designed for GPS-denied environments.
All autonomy capabilities are in design and development. None are currently deployed on operational platforms.